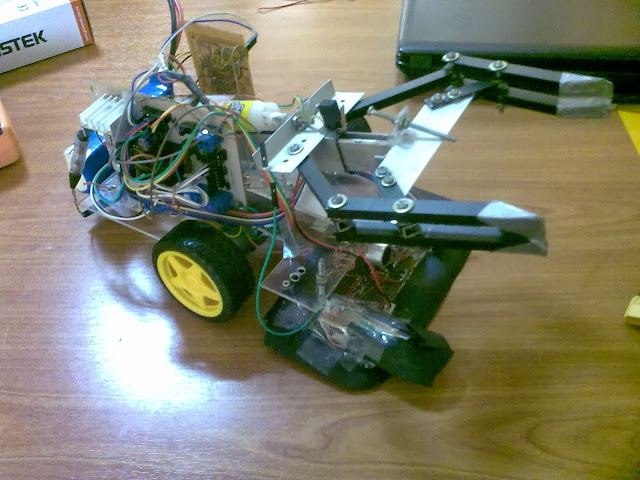
Line following and pick & place robot Get link Facebook X Pinterest Email Other Apps October 16, 2013 This was one of projects on our. The objective of this robot is to follow a line and when it find the box on the line it should pick-it-up and then it finds the mark on the track it should drop it. Read more